
 New
embodied-jev
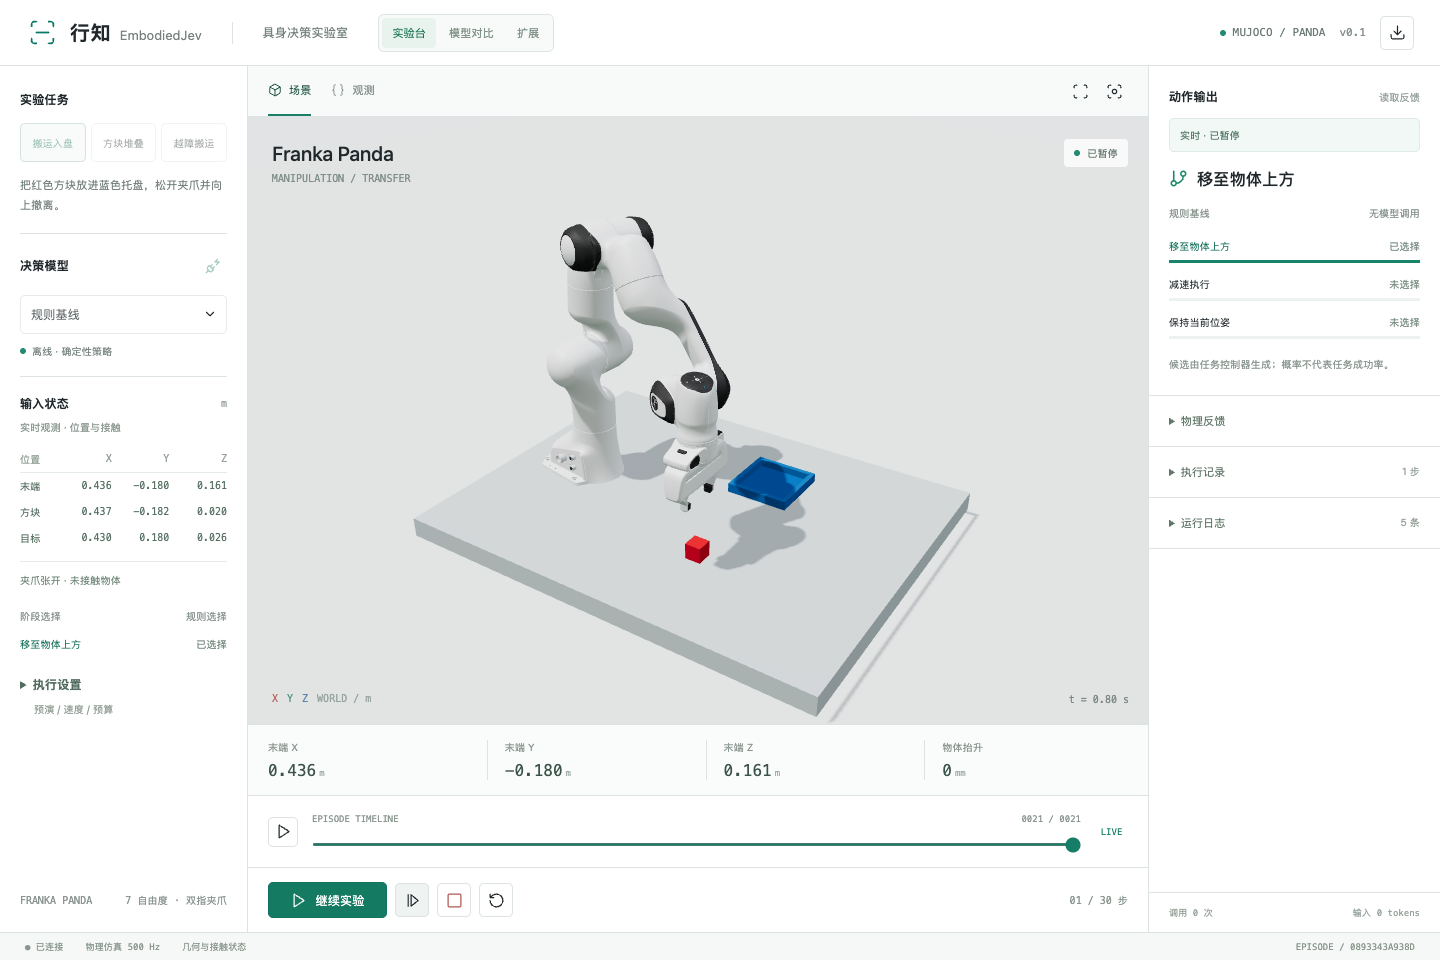
EmbodiedJev: MuJoCo robot decision workbench with MiniCPM5-2B, Jev and compatible model APIs.
Added to Jevfast
NewEmbodiedJev: MuJoCo robot decision workbench with MiniCPM5-2B, Jev and compatible model APIs.
In the documented layered XYZ setup, Jev receives simulator coordinates and contact feedback, selects a subgoal, then chooses axis directions and gripper action. The controller executes the step and returns updated observations for another decision.
Choose the finger command for the current subgoal.
Measured TCP, object, and destination coordinates plus the selected subgoal, target, signed errors, tolerance, and step limit are sent as state.
Read structured robot and scene measurements, optionally derived from local visual detection.
Jev selects a subgoal and then motion and gripper choices from the supplied state.
Apply the action in MuJoCo and feed the resulting state back into the next decision step.
The browser-based lab exposes physical feedback and decision stages while supporting configurable cameras and multiple model backends; Jev itself receives structured text rather than camera images.