
 New
New
How it uses Jev
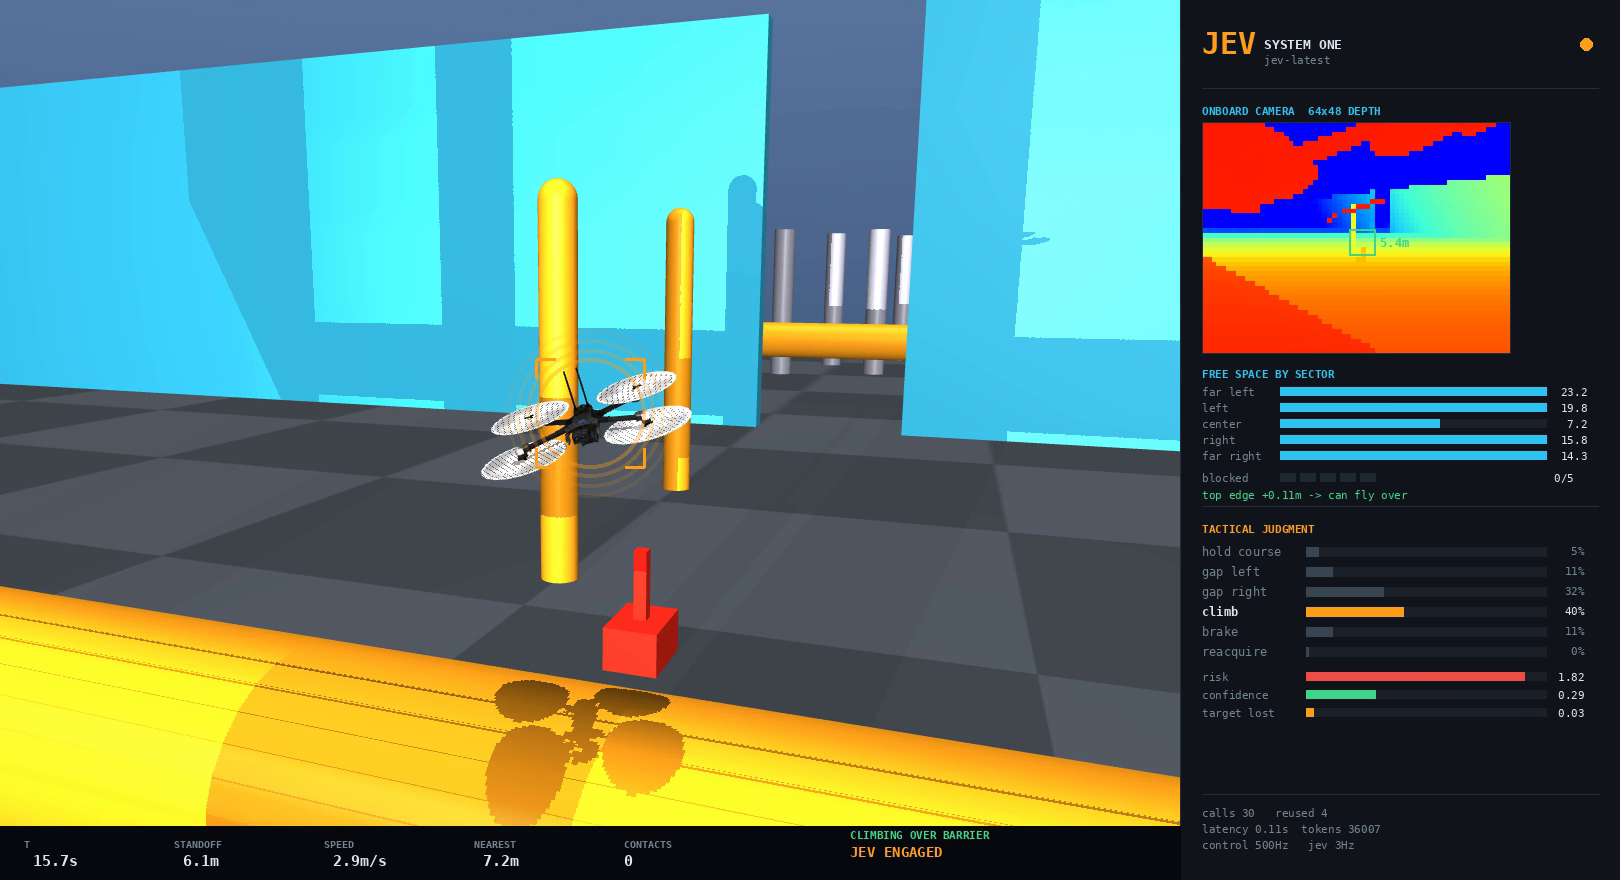
Classical vision converts camera depth and segmentation into a symbolic scene. Jev answers tactical maneuver and target-state questions at a slower cadence; code owns flight control and can veto unsafe maneuvers.
What Jev decides
Tactical maneuverExample answers · not a recorded Jev response · Source ↗
Question 1 · maneuver
YOUR APP
INSTRUCTION
Which single maneuver should the drone commit to right now?
STATE
Mission and aircraft configuration plus the observed scene, including obstacle sectors and target visibility.
JEV · CHOICE
- gap_left
- gap_right
- climb
- brake
- reacquire
Question 2 · risk
YOUR APP
INSTRUCTION
How dangerous is the drone's immediate situation?
STATE
Mission and aircraft configuration plus the observed scene, including obstacle sectors and target visibility.
JEV · SCORE
0
Question 3 · target truly lost
YOUR APP
INSTRUCTION
Has the drone genuinely lost the rover?
STATE
Mission and aircraft configuration plus the observed scene, including obstacle sectors and target visibility.
JEV · NOUL
YesNo
App workflow
- Derive a symbolic scene
Capture camera frames and derive obstacle sectors and target geometry.
- Request tactical judgment
Send the compact scene to Jev for a tactical judgment.
- Apply safety checks
Check the proposed maneuver against the safety reflex and current flight constraints.
- Control the aircraft
Pass the allowed maneuver to the 500 Hz guidance and control loop.
Why it is interesting
A typed tactical layer operates on a compact symbolic scene, with ordinary control code retaining the safety reflex and the fast flight loop.