
 New
Jev Reflex Autonomy Lab
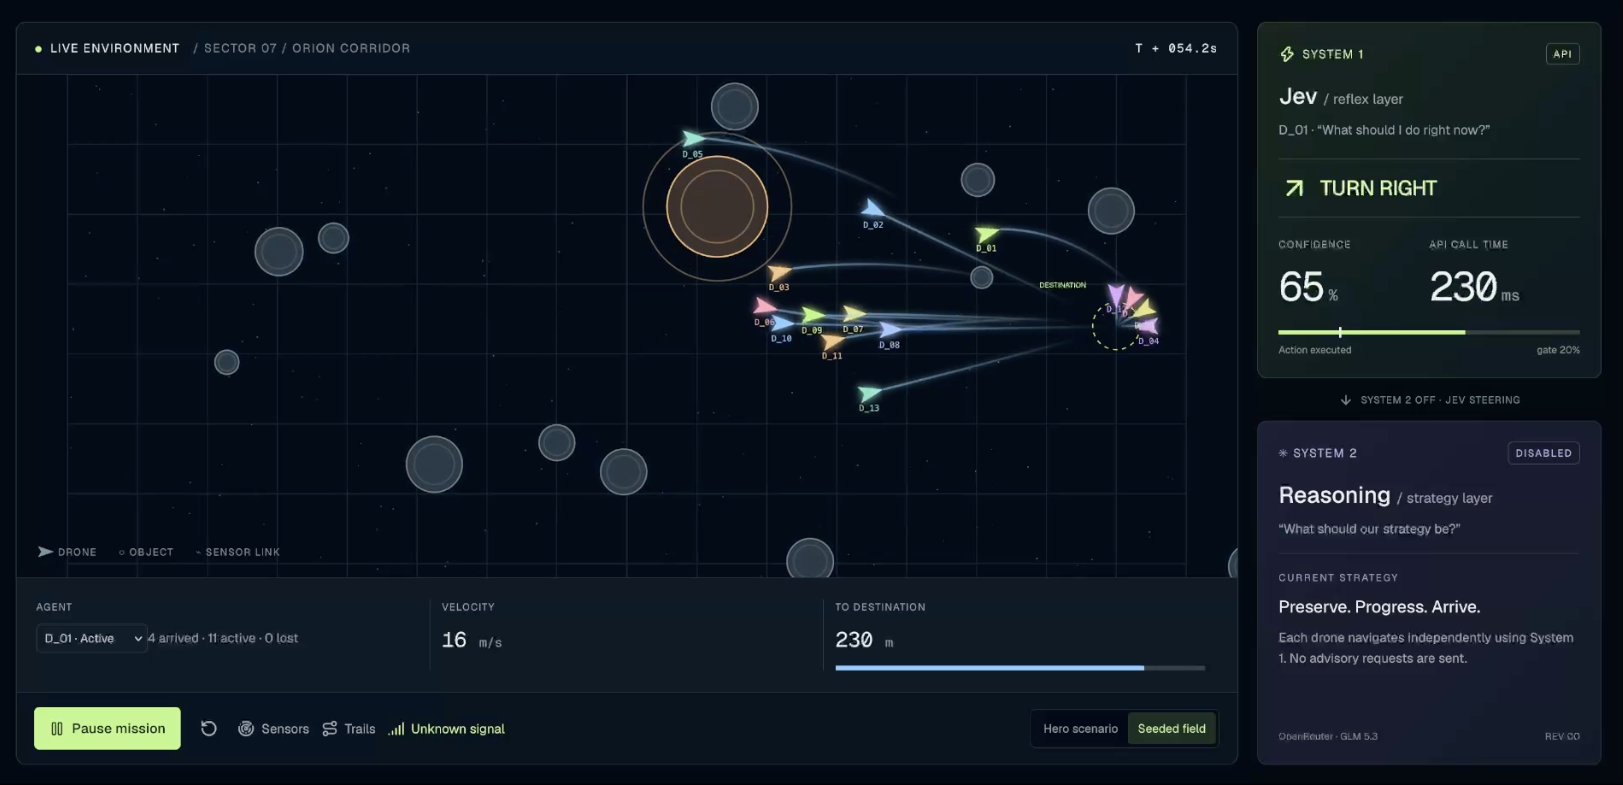
Simulate a drone fleet whose Jev reflex decisions can use optional strategic advice from a slower model.
Added to Jevfast
NewSimulate a drone fleet whose Jev reflex decisions can use optional strategic advice from a slower model.
The reflex controller builds a Jev request from the agent ID, mission, current observation, projected outcomes for available actions, control memory, and selected strategy settings. Jev returns an action Choice. The option set is dynamic: the code includes only actions with projections and removes RETREAT when at least one safe forward action exists. The controller parses the response and validates the chosen action before applying it.
Choose the single best next flight action, prioritizing collision avoidance and flight bounds, then safe strategy, then progress toward the destination.
State includes agent ID, mission, observation, action projections, control memory, strategy mode, preferred side, safety distance, scan requirement, and units. The action Choice contains only projected actions. The options below are representative: available projections vary by observation, and RETREAT is removed when any safe forward action exists. This is a source-derived example, not a captured flight or Jev answer. The full seven-option example represents a context with projections for all actions and no collision-free forward option.
The controller computes action projections from the current observation and removes RETREAT when a safe forward action exists.
It includes mission and observation state, projections, control memory, strategy, units, and a single action Choice with criteria for available projections.
The server checks the response type, action ID, probabilities, and expected option set, then passes the decision through the validator.
The action list is generated from the controller's own motion projections, so Jev chooses among actions the system can currently evaluate. The request also states safety priorities and policies, while response parsing and decision validation remain explicit code steps.